

The fifth edition of Servet will launch several helium balloons to the stratosphere, carrying capsules (linked together) made by different enthusiasts and makers. Three Hwoyee 1600 balloons will be used to launch around ten capsules which, depending on the weight and the amount of helium put into the balloons, will travel more or less far. The aim is to reach at least 32 km in altitude. The intention is to recover the payload that is launched, although this is not guaranteed.
Capsule information
LoRa capsule

Capsule linked to a ground base station, with info and ballast-release control on a mobile phone
Equipped with an electromagnet to release ballast to help the balloon climb if needed
Based on Arduino ESP32 Uno
Sensors: GPS, internal temperature
SD card
OLED screen
Electromagnet for ballast release
LoRa radio 1 W 868 MHz
Powered by two Li-ion batteries
Servet APRS capsule
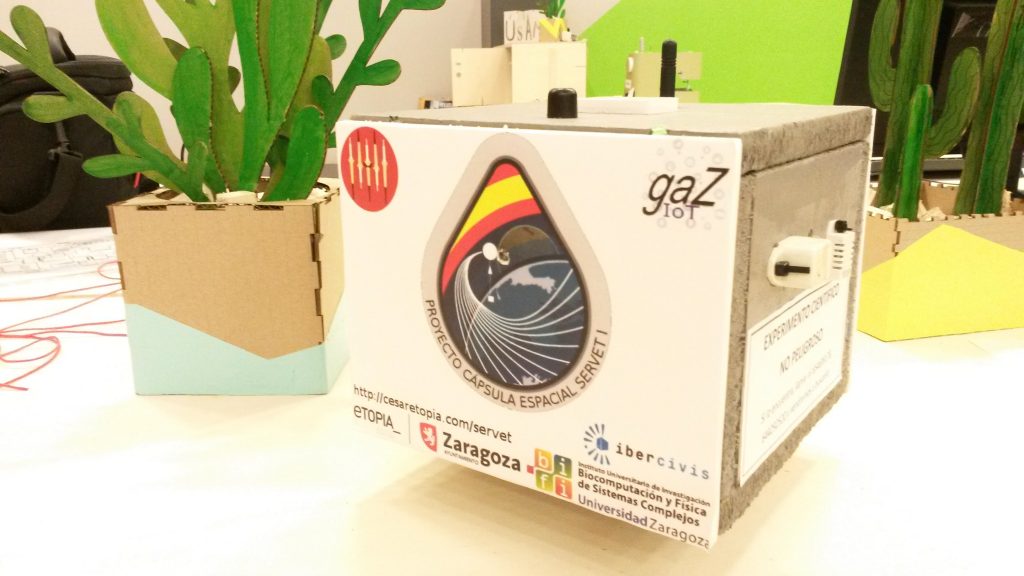
It has flown on every launch for APRS tracking
Based on Arduino Mega. Sensors: GPS, humidity, UV, interior and exterior temperature, atmospheric pressure, gyroscope
SD card, flip detector
LEDs
OLED screen
Buzzer
Short-range and long-range APRS radio on VHF
Powered by 12 AA lithium batteries
Chuck Norris Approved capsule
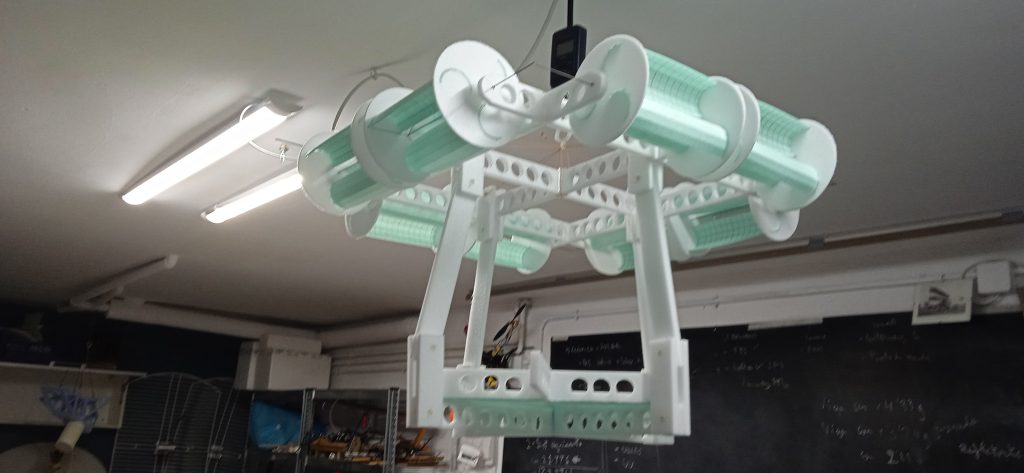
The two probes have finally been merged to share hardware and be able to carry more payload.
On the upper part, where the drums are, we will try to achieve stabilisation by the Magnus effect.
In addition, we will try to include a motor with conventional propellers and we will test some motors and servos to check how they work in near space.
It will also carry an inertial sensor and a GPS to measure the position and the angles of the three axes.
The base of the probe will carry the second probe proper, in which we will put the potato and a series of sensors that measure environmental conditions.
It will also have a 4K camera, a LoRaWAN tracker system and a LoRa backup one that also sends us information about the system.
GALtidude
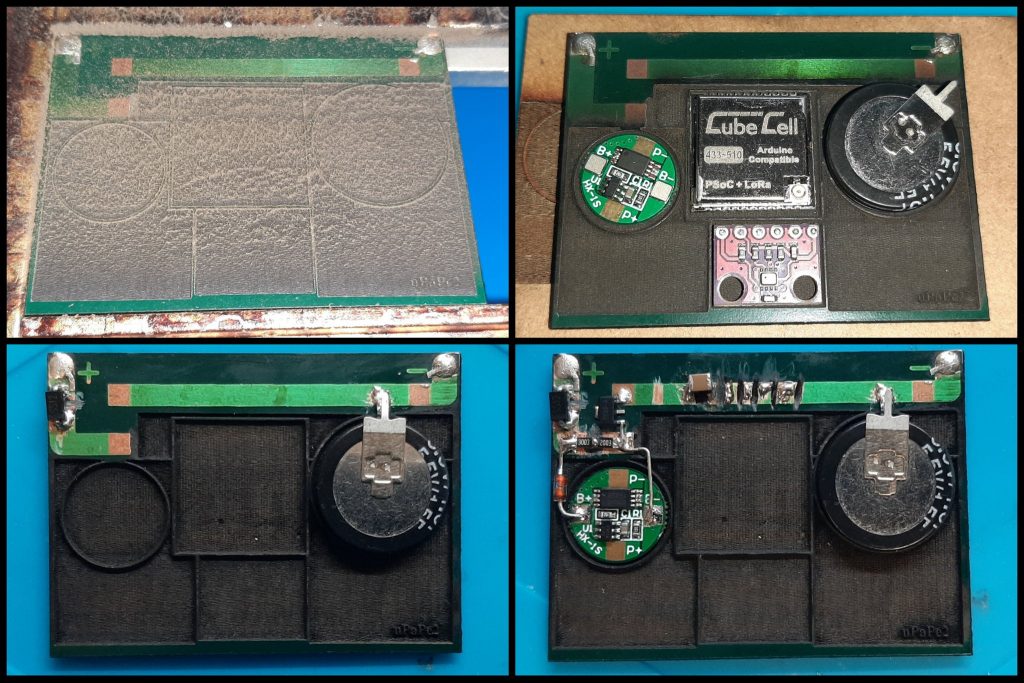
Performance comparison of a GPS-based location system against a GALILEO-based system, taking into account altitudes of 0-35 km.
Its aim is to demonstrate that a GALILEO-only GNSS system is accurate and reliable for HAPS (High Altitude Pseudo-Satellites).
PongPod
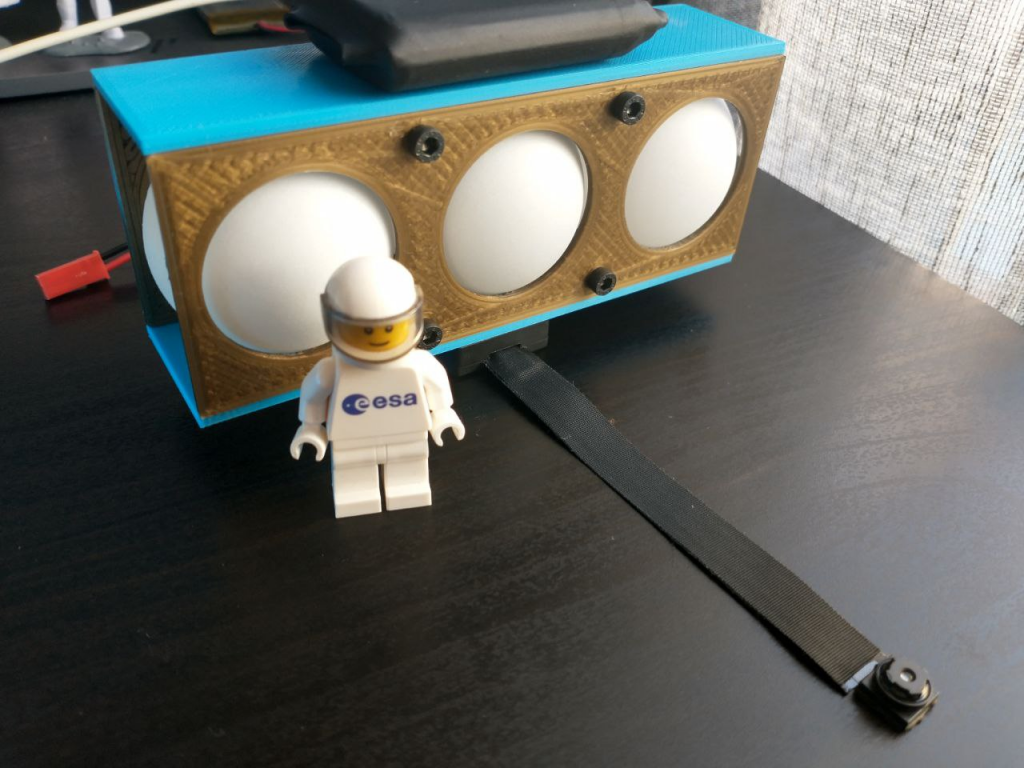
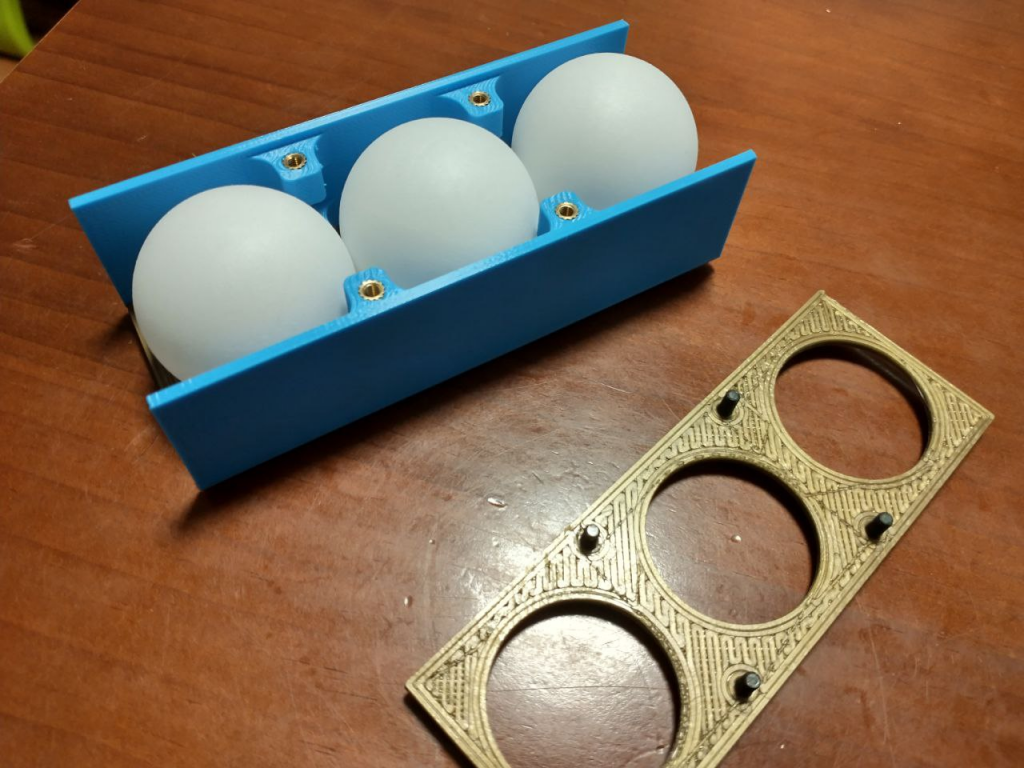
PongPod is an educational platform for taking “nanosatellites” and “nano space tourists” to the stratosphere in the form of small ping-pong balls. For this mission the capsule will carry three “nano tourists” and a camera that will take “selfies” of the capsule itself. It is a project by Juampe López.
Servet Fluids
There will be different test tubes containing some liquids (water, oil, alcohol and 2 more to be chosen). They will be in one part of the polystyrene capsule, uncovered at the top. In the other part a camera will be placed recording the test tubes, together with an Arduino system for communication.
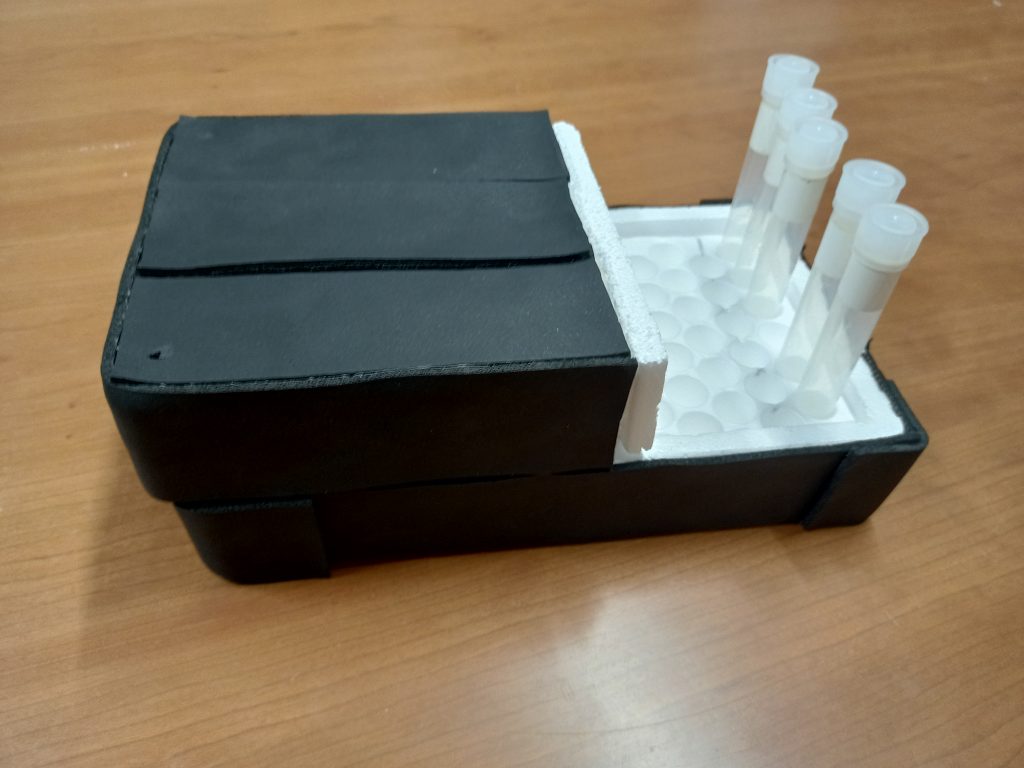
On the electronics side there will be a temperature and humidity sensor connected to the Arduino board and to a LoRa antenna to send the sensor data to the monitoring Arduino on the ground.
The launch site for the capsules will be announced in the coming days.